 WhiteLabelUSV

Six-sector vessel awareness
NavCam coverage for port-bow, bow, starboard-bow, starboard-quarter, stern and port-quarter.
Operator assurance
In development2ndHelm is being developed for situational awareness, manual recovery and emergency vessel control.
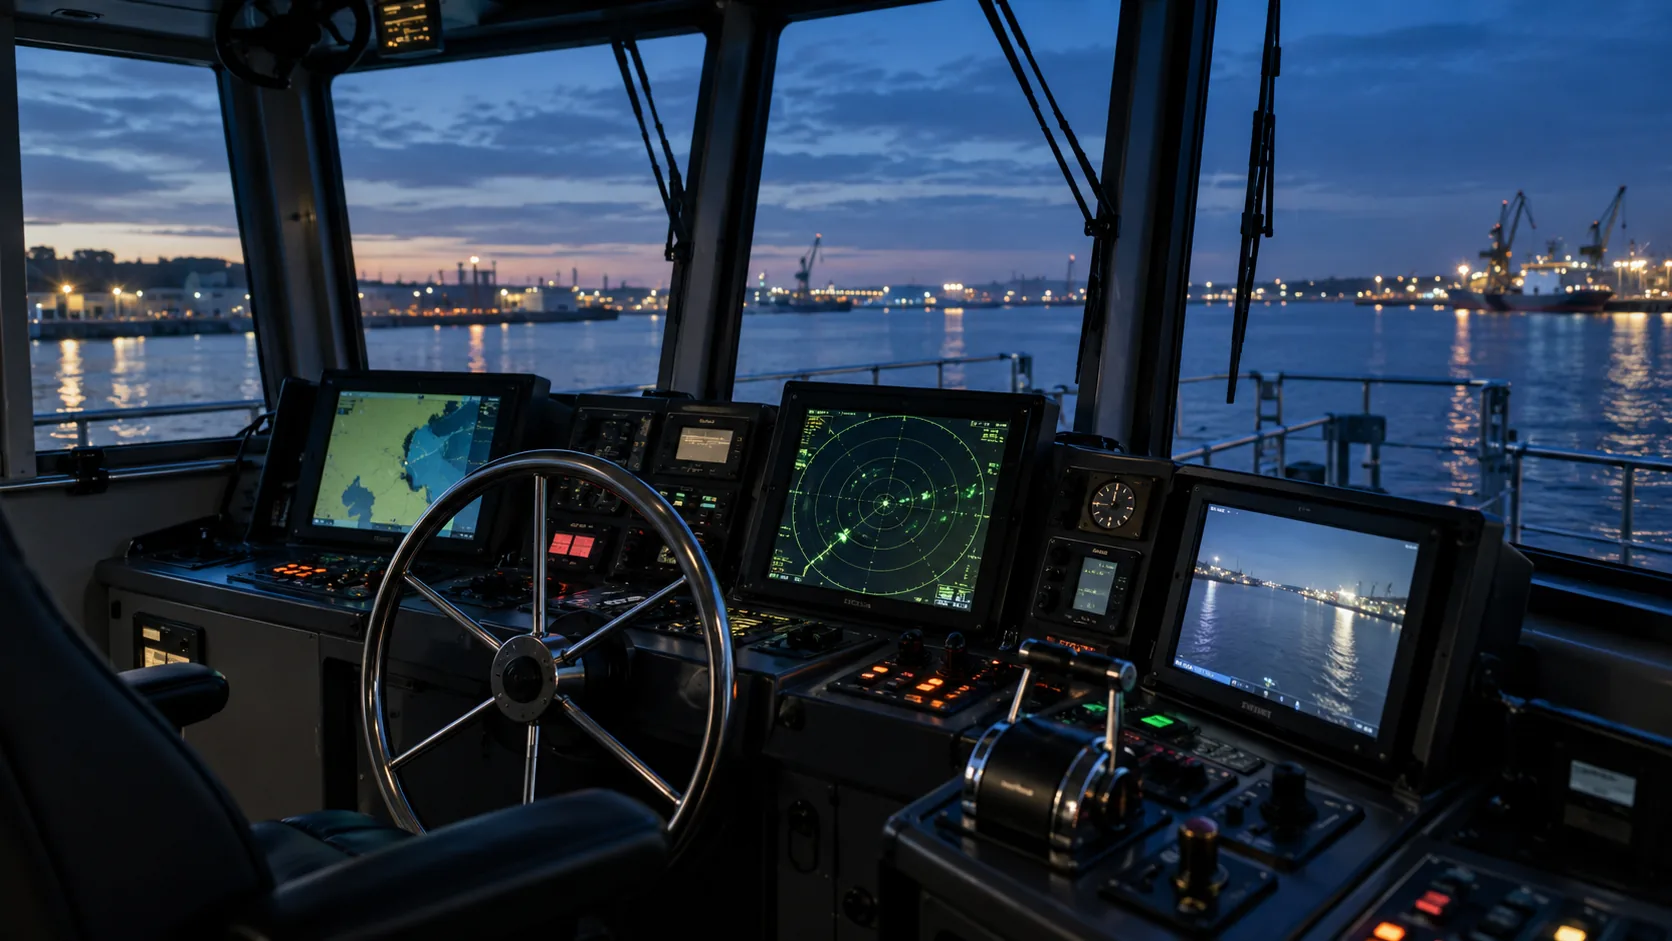
The role of 2ndHelm
The transition toward autonomy needs a defined operator-assurance layer.
2ndHelm’s development scope brings vessel context, supervision and recovery controls together. The focus is a clear operator view backed by explicit health and recovery behaviour.
Discuss your vessel’s requirements and development fit. 2ndHelm is not offered here as a production-ready safety system.
Coverage concept · not a live feed or product screenshot
NavCam development
Explore the intended camera coverage around the vessel.
Forward vessel context.
A separate chart view brings together vessel position, heading, course, speed, wake and follow-vessel behaviour.
Development priorities
NavCam coverage for port-bow, bow, starboard-bow, starboard-quarter, stern and port-quarter.

Position, heading, course, speed, wake and follow-vessel behaviour in the operator view.

Request and release control, throttle, steering, dead-man input and emergency-stop integration.

Separate liveness from freshness, with defined degraded and offline states.

Isolate failed sources, reconnect or restart where supported, and verify recovery.

Record faults, transitions, retries and authorised operator actions for review.
Programme discussion
What does the vessel need the operator to see and control, and under which conditions?
Which timeouts, command limits and fail-safe responses apply to each subsystem?
How will the team exercise stale data, dropped connections, restarts and manual intervention?
Product questions
2ndHelm is in development. Discuss the current scope and programme fit directly; it is not listed as an available evaluation download.
It is being developed as an operator-assurance and recovery layer alongside vessel automation, rather than as a claim of complete autonomous navigation.
The development scope includes liveness probes, connection health, data freshness, degraded states, reconnect/restart behaviour and recovery verification.
No universal recovery guarantee is made. The vessel needs defined fault responses, control authority and manual-intervention conditions, verified through testing.
Let’s start with your vessel
Help shape the developing 2ndHelm layer around your controls, cameras, communications and recovery requirements.